Porisma

Original question & working

Planes containing a prescribed line · source reference

[2010/CJC/Prelim/II/2] · Question pp. 5 · Working pp. 24, 25, 26

Open the interactive lesson

The working and teaching notes are included in the interactive lesson.

View source review notes
Full original question, working & notes

Printed question

The equations of the line l1l_1 and the plane p1p_1 are respectively, r=(1,0,0)+μ(−1,1,1)\mathbf r=(1,0,0)+\mu(-1,1,1) and r=s(1,1,1)+t(2,−1,1)\mathbf r=s(1,1,1)+t(2,-1,1), where μ,s,t∈R\mu,s,t\in\mathbb R.

(i) Find the acute angle between l1,p1l_1,p_1. [3]

(ii) A second plane p2p_2 has equation r⋅(α,1,β)=1\mathbf r\cdot(\alpha,1,\beta)=1. Given that the two planes p1,p2p_1,p_2 intersect at the line l2:4x−15−2=y,z=52l_2:\frac{4x-15}{-2}=y,z=\frac52, find the values of α,β\alpha,\beta. [3]

(iii) The plane p3p_3 with equation 2x+by+z=12x+by+z=1 is parallel to l2l_2. Find the value of bb. Hence find the distance between l2,p3l_2,p_3. [4]

[2010/CJC/Prelim/II/2]

Printed working

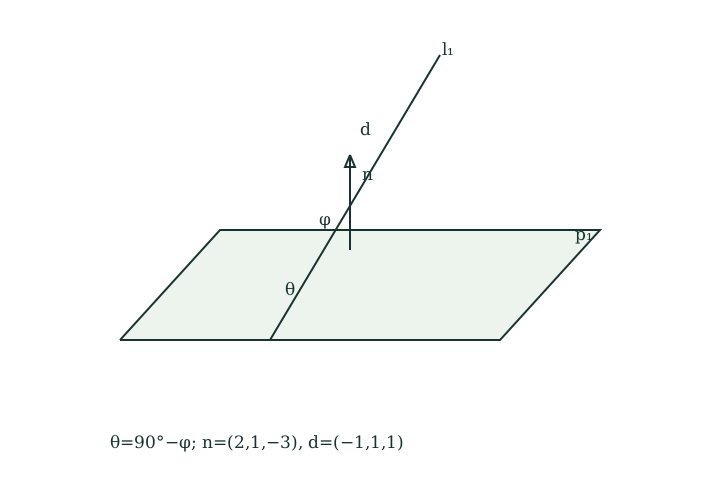
(i) A normal to p1=(1,1,1)×(2,−1,1)=(2,1,−3)p_1=(1,1,1)\times(2,-1,1)=(2,1,-3).

A direction vector of l1=(−1,1,1)l_1=(-1,1,1).

Acute angle between l1l_1 and normal of p1p_1

=cos⁡−1∣(2,1,−3)⋅(−1,1,1)∣(4+1+9)(1+1+1)=51.9∘=\cos^{-1}\frac{|(2,1,-3)\cdot(-1,1,1)|}{\sqrt{(4+1+9)(1+1+1)}}=51.9^\circ.

Hence acute angle between l1,p1=90∘−51.9∘=38.1∘l_1,p_1=90^\circ-51.9^\circ=38.1^\circ (to 1 d.p.).

(ii) p2:r⋅(α,1,β)=1p_2:\mathbf r\cdot(\alpha,1,\beta)=1.

l2:r=(15/4,0,5/2)+a(−1,2,0)l_2:\mathbf r=(15/4,0,5/2)+a(-1,2,0) lies on p1,p2p_1,p_2.

Thus l2l_2 is perpendicular to normal of p2p_2 and (15/4,0,5/2)(15/4,0,5/2) lies in p2p_2.

⇒(−1,2,0)⋅(α,1,β)=0⇒−α+2=0⇒α=2\Rightarrow(-1,2,0)\cdot(\alpha,1,\beta)=0\Rightarrow-\alpha+2=0\Rightarrow\alpha=2.

and (15/4,0,5/2)⋅(α,1,β)=1⇒154α+52β=1⇒β=−135(15/4,0,5/2)\cdot(\alpha,1,\beta)=1\Rightarrow\frac{15}4\alpha+\frac52\beta=1\Rightarrow\beta=-\frac{13}5.

Printed alternative solution

(15/4,0,5/2)(15/4,0,5/2) and (4,−1/2,5/2)(4,-1/2,5/2) (using a=−14a=-\frac14) are two points on line l2l_2, and thus are points on p2p_2.

Substituting each point in equation of plane,

3.75α+2.5β=13.75\alpha+2.5\beta=1 — (1).

3.25α+2.5β=03.25\alpha+2.5\beta=0 — (2).

Using GC, α=2,β=−2.6\alpha=2,\beta=-2.6.

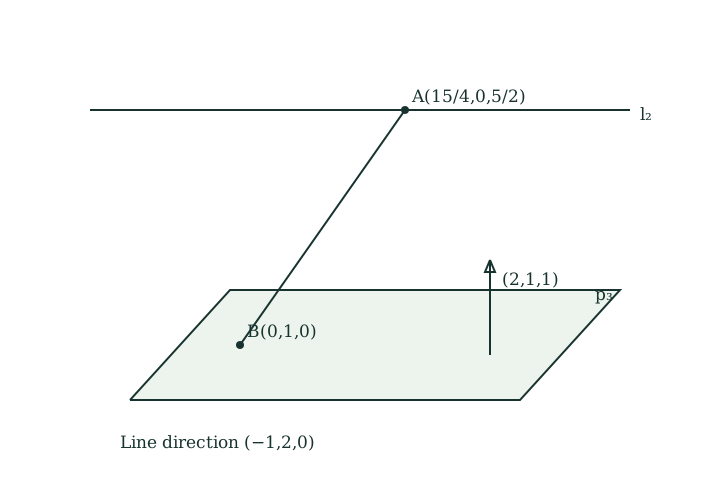
(iii) p3p_3 is parallel to l2⇒l_2\Rightarrow direction vector of l2l_2 is perpendicular to normal of p3p_3.

(2,b,1)⋅(−1,2,0)=0⇒b=1(2,b,1)\cdot(-1,2,0)=0\Rightarrow b=1.

∴\therefore Equation of plane p3:r⋅(2,1,1)=1p_3:\mathbf r\cdot(2,1,1)=1.

Observe that B(0,1,0)B(0,1,0) is a point on p3p_3.

AB→=(0,1,0)−(15/4,0,5/2)=(−15/4,1,−5/2)\overrightarrow{AB}=(0,1,0)-(15/4,0,5/2)=(-15/4,1,-5/2).

Thus, distance between l2,p3=l_2,p_3= perpendicular distance from AA to p3p_3

=∣AB→⋅(2,1,1)∣∣(2,1,1)∣=14+1+1∣(−15/4,1,−5/2)⋅(2,1,1)∣=∣−15/2+1−5/2∣6=96=362=\frac{|\overrightarrow{AB}\cdot(2,1,1)|}{|(2,1,1)|}=\frac1{\sqrt{4+1+1}}|(-15/4,1,-5/2)\cdot(2,1,1)|=\frac{|-15/2+1-5/2|}{\sqrt6}=\frac9{\sqrt6}=\frac{3\sqrt6}2.

Native source teaching diagram, Q17 angle Native source teaching diagram, Q17 distance

Teacher notes

Let θ\theta be the acute angle between a line and a plane l1:r=a+λdl_1:\mathbf r=\mathbf a+\lambda\mathbf d, p1:r⋅n=pp_1:\mathbf r\cdot\mathbf n=p.

cos⁡ϕ=∣d⋅n∣∣d∣∣n∣\cos\phi=\frac{|\mathbf d\cdot\mathbf n|}{|\mathbf d||\mathbf n|}; θ=90∘−ϕ\theta=90^\circ-\phi.

B(0,1,0)B(0,1,0) is a point on p3p_3 since it satisfies equation of p3p_3.

Printed answer key

(i) 38.1∘38.1^\circ (to 1 d.p.). (ii) α=2,β=−135\alpha=2,\beta=-\frac{13}5. (iii) b=1b=1; 362\frac{3\sqrt6}2.

Editorial qualification

The printed alternative point (4,−1/2,5/2)(4,-1/2,5/2) correctly uses a=−1/4a=-1/4. Its second scalar equation is a source typo: substituting this point gives 4α+2.5β=3/24\alpha+2.5\beta=3/2, rather than the printed 3.25α+2.5β=03.25\alpha+2.5\beta=0. Together with the first equation, the corrected system still gives α=2,β=−13/5\alpha=2,\beta=-13/5.

Source provenance

2025 TJC H2 Math (9758) JC2 MSM: VECTORS. Question booklet PDF pages 4–12 (printed 80–88); solution booklet PDF pages 17–44. Column vectors are typeset as ordered coordinate triples here; the entries, products, intermediate equations and original parameter/domain restrictions are retained.